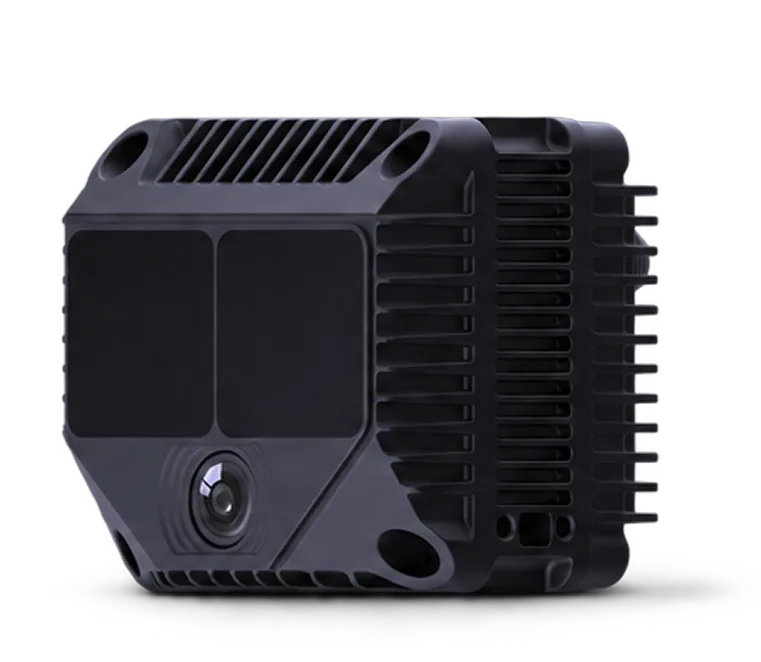
dToF · Depth
01 / 07- Depth resolution
- 240 × 180
- Max. range (reflectivity)
- 25 m @10% (<50 klux) / 50 m @90% (<500 lux)
- Min. range
- 0.15 m
- Point rate
- Up to 430,000 pts/s
- Range accuracy
- ±3 cm @1σ [1]

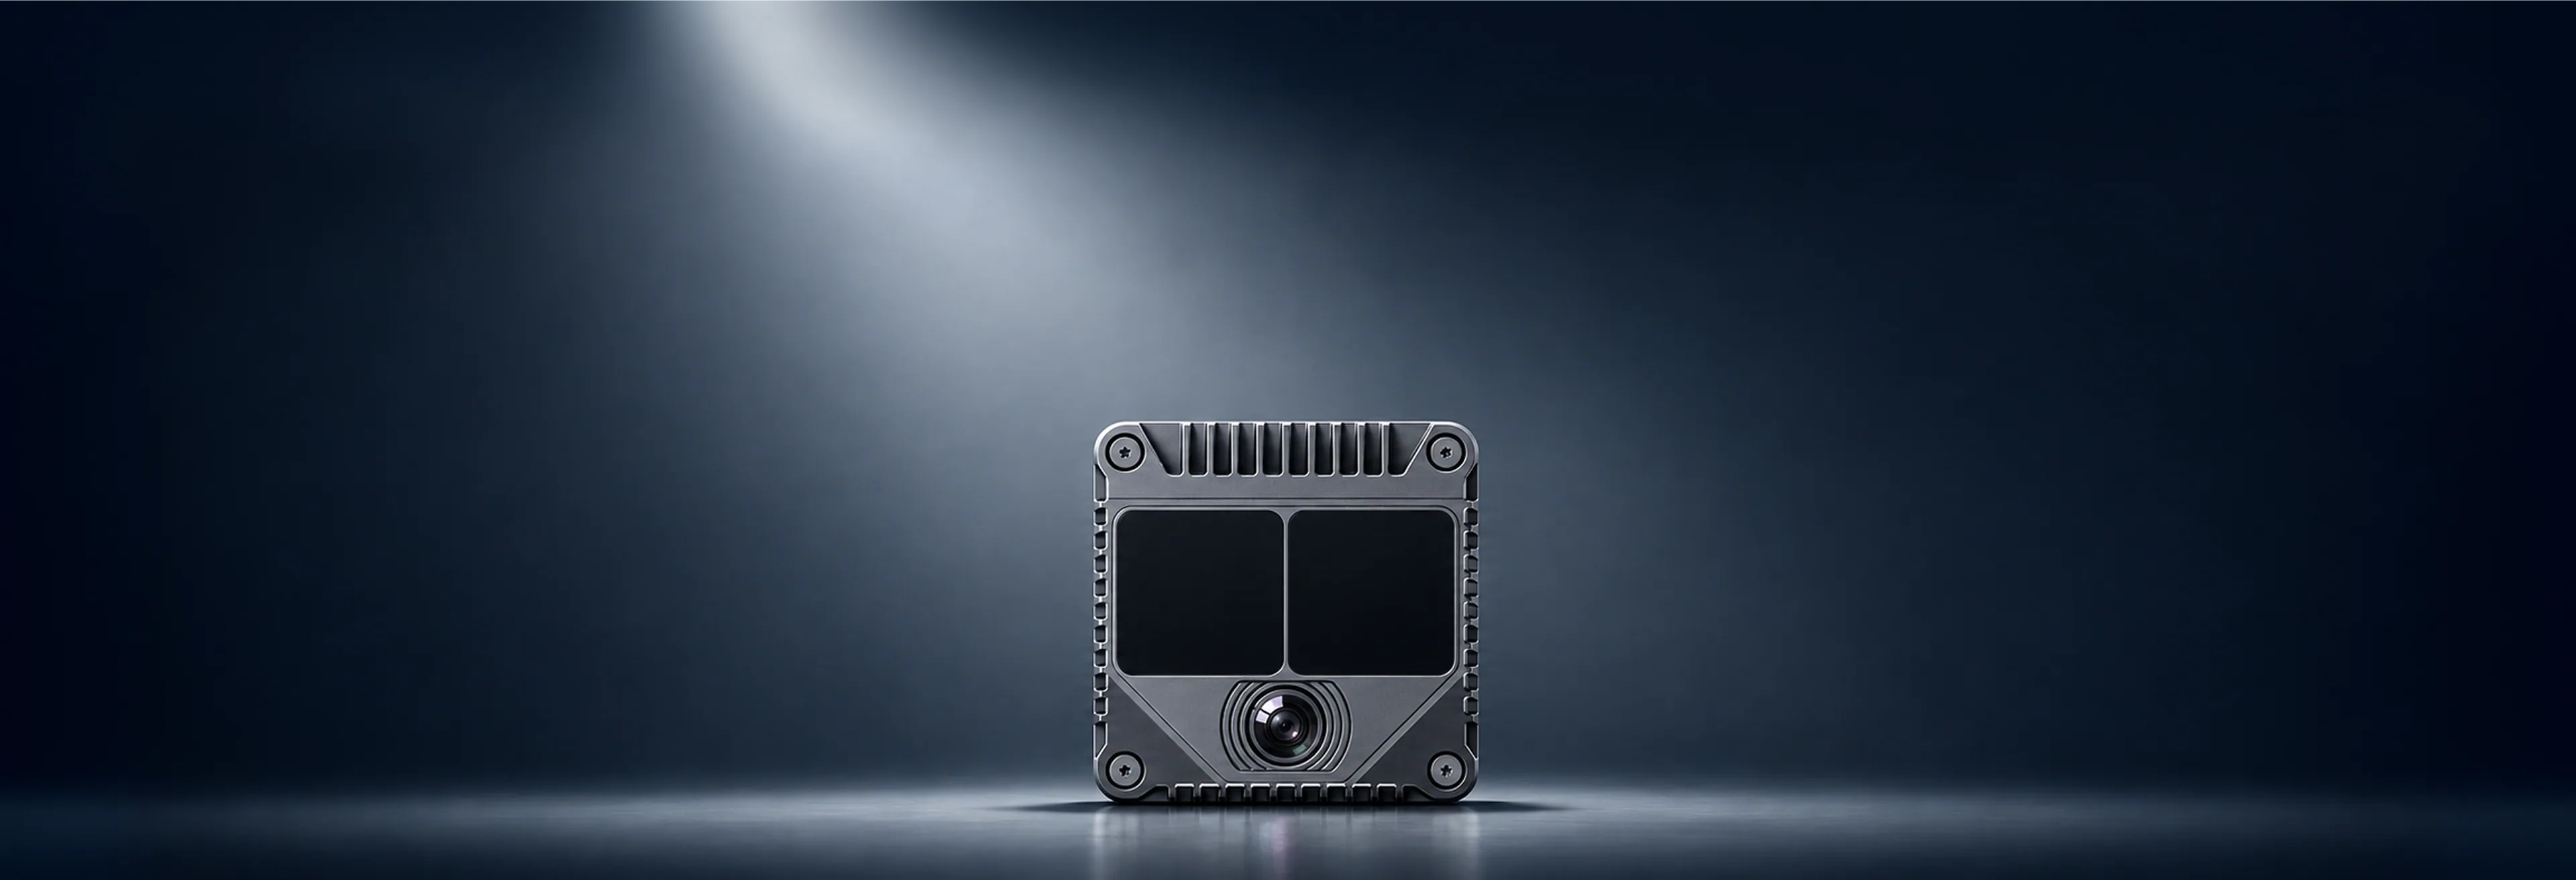
Get real-time pose, point clouds and motion trajectories from one compact module. Odin1 Lite combines RGB, IMU and LiDAR with onboard MindSLAM™ — so you can focus on your application.
# ODIN ROS Driver — Quick Start

Requires an installed and sourced ROS 2 environment (Humble or Jazzy).

## 1. Get the driver

```bash
mkdir -p ~/odin_ws/src && cd ~/odin_ws/src
git clone --recurse-submodules <DRIVER_REPO_URL> ros_driver
```

The folder name must be `ros_driver` and it must sit directly under `~/odin_ws/src`.

## 2. Build

```bash
cd ~/odin_ws
source /opt/ros/humble/setup.bash
./src/ros_driver/script/build_ros2.sh
source install/setup.bash
```

On low-memory hosts, limit the build parallelism: `ODIN_BUILD_JOBS=2 ./src/ros_driver/script/build_ros2.sh`

## 3. Run

```bash
cd ~/odin_ws && source install/setup.bash

# Odin1Lite (single camera) / Odin2Special (dual camera)
ros2 launch odin_ros_driver_rev1 odin1Lite.launch.py
```

## 4. Get data

Open a second terminal:

```bash
cd ~/odin_ws && source install/setup.bash

ros2 topic hz /manifold/device0/cloud/raw
ros2 topic hz /manifold/device0/camera0/compressed
ros2 topic echo /manifold/device0/imu --once
```

## Launch options

| Option | Purpose |
| --- | --- |
| `device_ip:=192.168.1.251` | Skip broadcast discovery when the device IP is known |
| `start_rviz:=false` | Run without RViz |
| `image_width:=640 image_height:=544 image_fps:=30` | Select image resolution and frame rate |
| `tf_publish_rate:=50.0` | Republish TF at a fixed rate for RViz |

## Topics

Default prefix `/manifold/device0/`:

`cloud/raw`, `cloud/slam`, `camera0/compressed`, `camera1/compressed`, `imu`, `odometry_lf`, `odometry_hf`
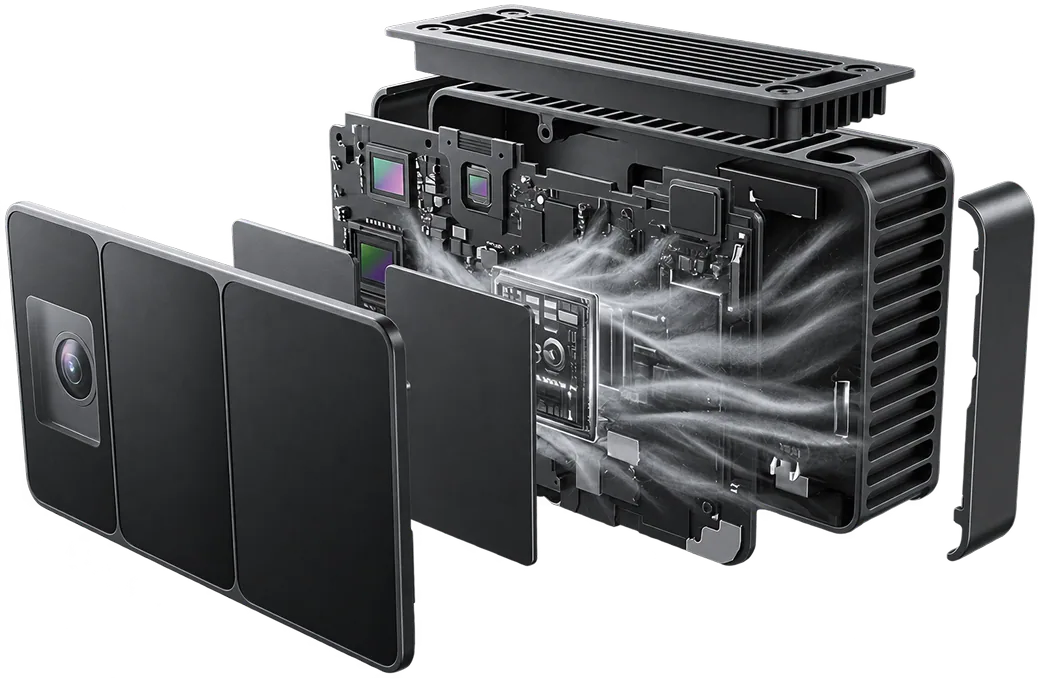
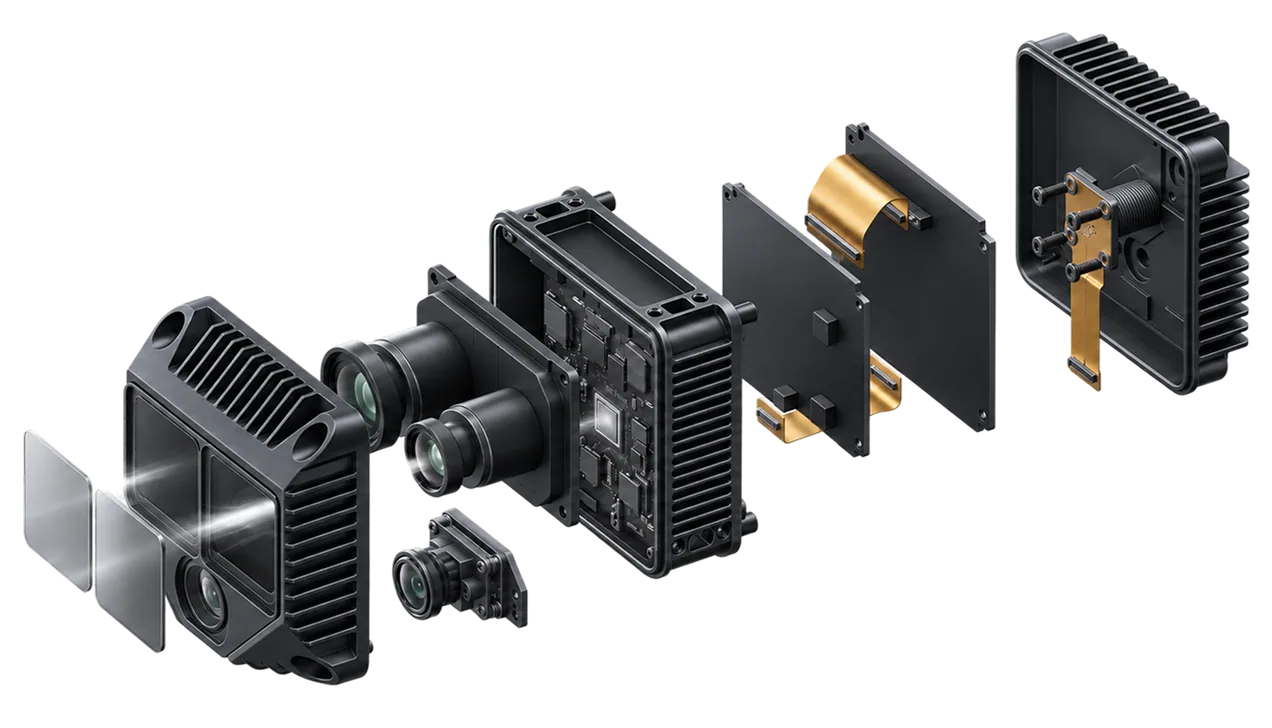
Integrating depth perception with visual information to provide a hardware foundation for spatial intelligence
Adaptive Mode Switching - dToF Dual Mode
Clearer at greater distances outdoors
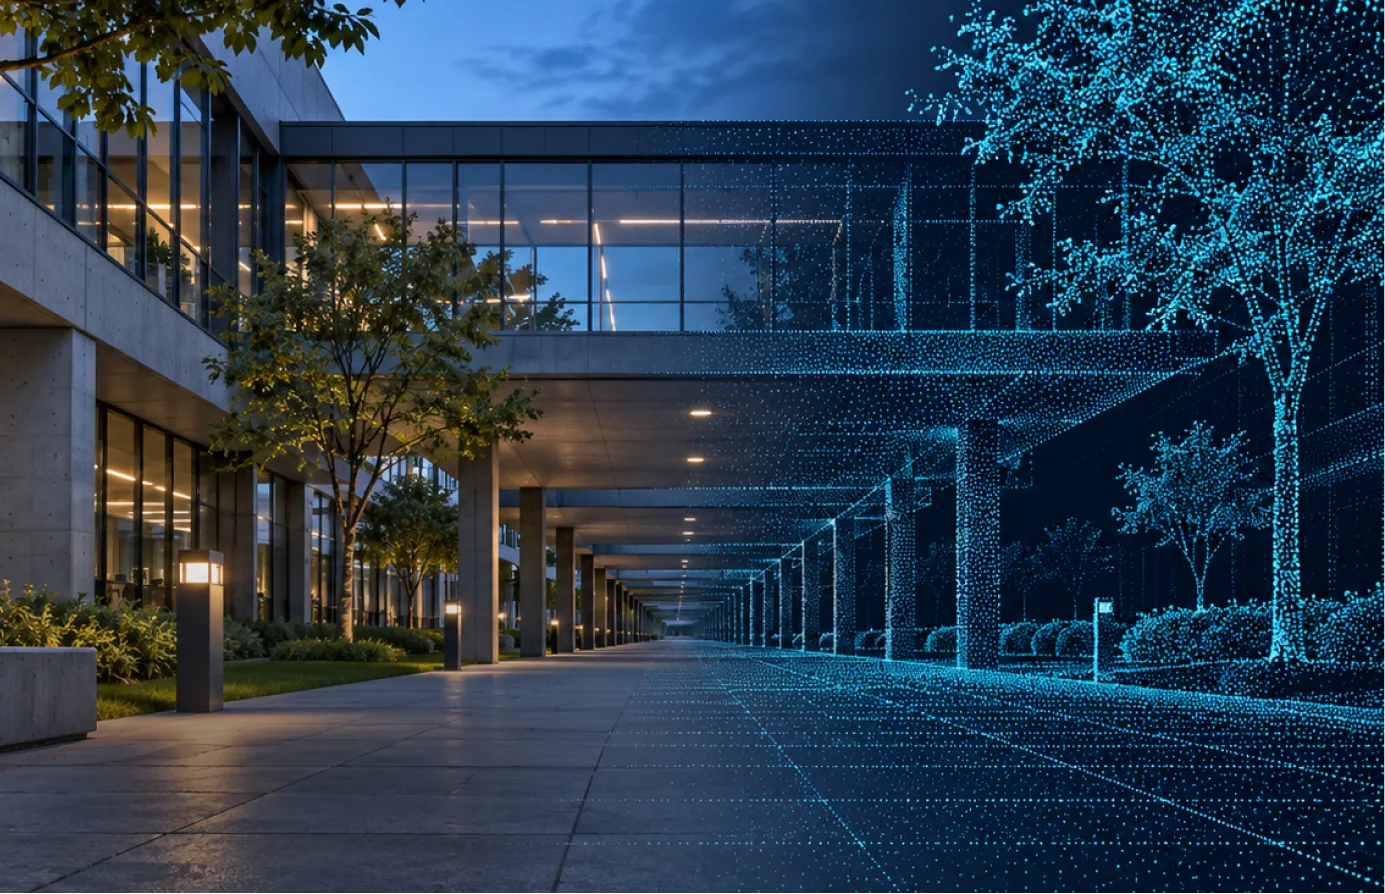
Laser-enhanced Visual Odometry
All-time, All-domain 3D Positioning
Odin1 Lite · Swipe to view full specs →
| Parameter Name | Parameter Name | Specifications / Values |
|---|---|---|
| dToF Depth Module | Depth Resolution | 240 × 180 |
| Measurement Range (Max) | 25m @10% Reflectivity (<50Klux) / 50m @90% Reflectivity (<500lux) | |
| Measurement Range (Min) | 0.15m | |
| Point Frequency | Up to 430,000 pts/s | |
| Measurement Accuracy | ±3 cm @ 1σ [1] | |
| Field of View (FOV, Horizontal × Vertical) | 120° × 90° | |
| Angular Resolution | 0.5° × 0.5° | |
| Laser Wavelength | 940 nm | |
| Laser Safety Class | Class 1 Eye Safe | |
| Frame Rate | Up to 10 FPS | |
| RGB Camera Module | Resolution | 1280 * 1088 |
| Exposure Method | Global Exposure (Global Shutter) | |
| FOV (H × V) | 121° H × 106° × 151° D | |
| Overall Parameters | Built-in SLAM Positioning Accuracy | ±2 cm + 0.2% [2] |
| Weight | 274 g | |
| Dimensions (L × W × D) (mm) | Approximately 69 mm × 69 mm × 58/66 mm (including aviation connector) | |
| Power Consumption | Rated 11 W, Peak 24 W | |
| Protection Level | IP66 | |
| Shock Resistance | 50 G × 5 ms | |
| Operating Voltage | 9-24 V | |
| Operating Temperature | -20°C ~ 45°C | |
| Storage Temperature | -20°C ~ 60°C | |
| Data Output | Point Cloud | True Color SLAM/Raw Point Cloud |
| Photo | Raw RGB Image | |
| IMU | High Frequency Raw Data | |
| Pose | High Frequency Rotation and Position Data | |
| MindCloud Platform Features | Global Optimization | |
| Generate MESH Texture Files | ||
| Supports output of 3D results in mainstream formats such as .las, .obj, .e57, .usd, etc. | ||
| Seamless integration with NVIDIA Omniverse | ||